
About TKK


About TKK
Striving to drive change in the world of work with robotic technology, automation
and AI to enhance the potential and efficiency of personnel to be able to work.
fully

Industrial Goods
Industrial Goods
Striving to drive change in the world of work with robotic technology, automation
and AI to enhance the potential and efficiency of personnel to be able to work.
fully

Solutions
Quotation
Shop Industrial Products
News
Work with us

Downloads
Catalogues
Catalogues
กรอกข้อมูลเพื่อรับแคตตาล็อก

Oops! Something went wrong while submitting the form.

เกี่ยวกับ TKK

ประวัติความเป็นมาของ ทีเคเค

พลังขับเคลื่อนองค์กร
โครงสร้างองค์กร
รางวัลแห่งความภาคภูมิใจ
พาร์ทเนอร์และคู่ค้า
ที่ตั้งสำนักงาน
เยี่ยมชม
สินค้าอุตสาหกรรม
Cutting Tools & Machining Tools
Factory Automation
Fluid Transfer & Lubrication
Linear Motion & Bearings
Motors, Gear & Transmission
Panels, Electrical Controls, Cabinets & Wiring
Pneumatics & Hydraulics
Pump, Blower & Vacuum Systems
Sensor & Control Systems
Smart Warehouse & Logistics Robots
งานบริการและโซลูชั่น
ขอใบเสนอราคา
ช้อปสินค้าอุตสาหกรรม
ข่าวสารองค์กร
ร่วมงานกับเรา
ติดต่อเรา
OMRON
CJ1W-NC[][]3
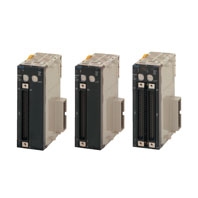
Type
Model :
CJ1W-NC[][]3
Screw diameter for both ends:
-
Applicable fluid:
-

Features
- Two types to choose from: open collector output and line driver. Because both open collector output and line driver types feature 1-, 2-, and 4-axis models, the most appropriate model can be selected for the application at hand.
- Positioning START occurs within 2 ms (maximum speed) after receiving a command from the Programmable Controller.
- High-speed data transfer is possible using INTELLIGENT I/O WRITE (IOWR) and INTELLIGENT I/O READ (IORD) instructions.
- Fine control from low to high speed (500 kpps max.) is possible in 1-pps units.
- Positioning can be done from memory, by writing an operating pattern into the PCU memory in advance. Three position patterns − Terminating, Automatic, and Continuous − can be set with completion codes to respond to a wide range of operations. Positioning of up to 100 patterns (sequential data) per one axis can be possible.
- Positioning (direct operation) can be done by direct PLC ladder commands for position data, speed data, and acceleration data. This simplifies control in situations when the target position and speed cannot be decided until immediately before operation begins, or when the target position and speed change due to other circumstances. The target position and speed can also be changed during operation.
- Interrupt feeding moves the axis a specified amount, then stops it, in accordance with an interrupt input. High-speed (0.1 ms max.) processing of the interrupt input signal ensures high-precision interrupt positioning. This helps to maximize feeder precision.
- Easy-to-Use positioning can be possible with versatile functions such as Teaching, Override, Backlash compensation, Zones, Forced interrupt and Acceleration/Deceleration curve.
Application


